
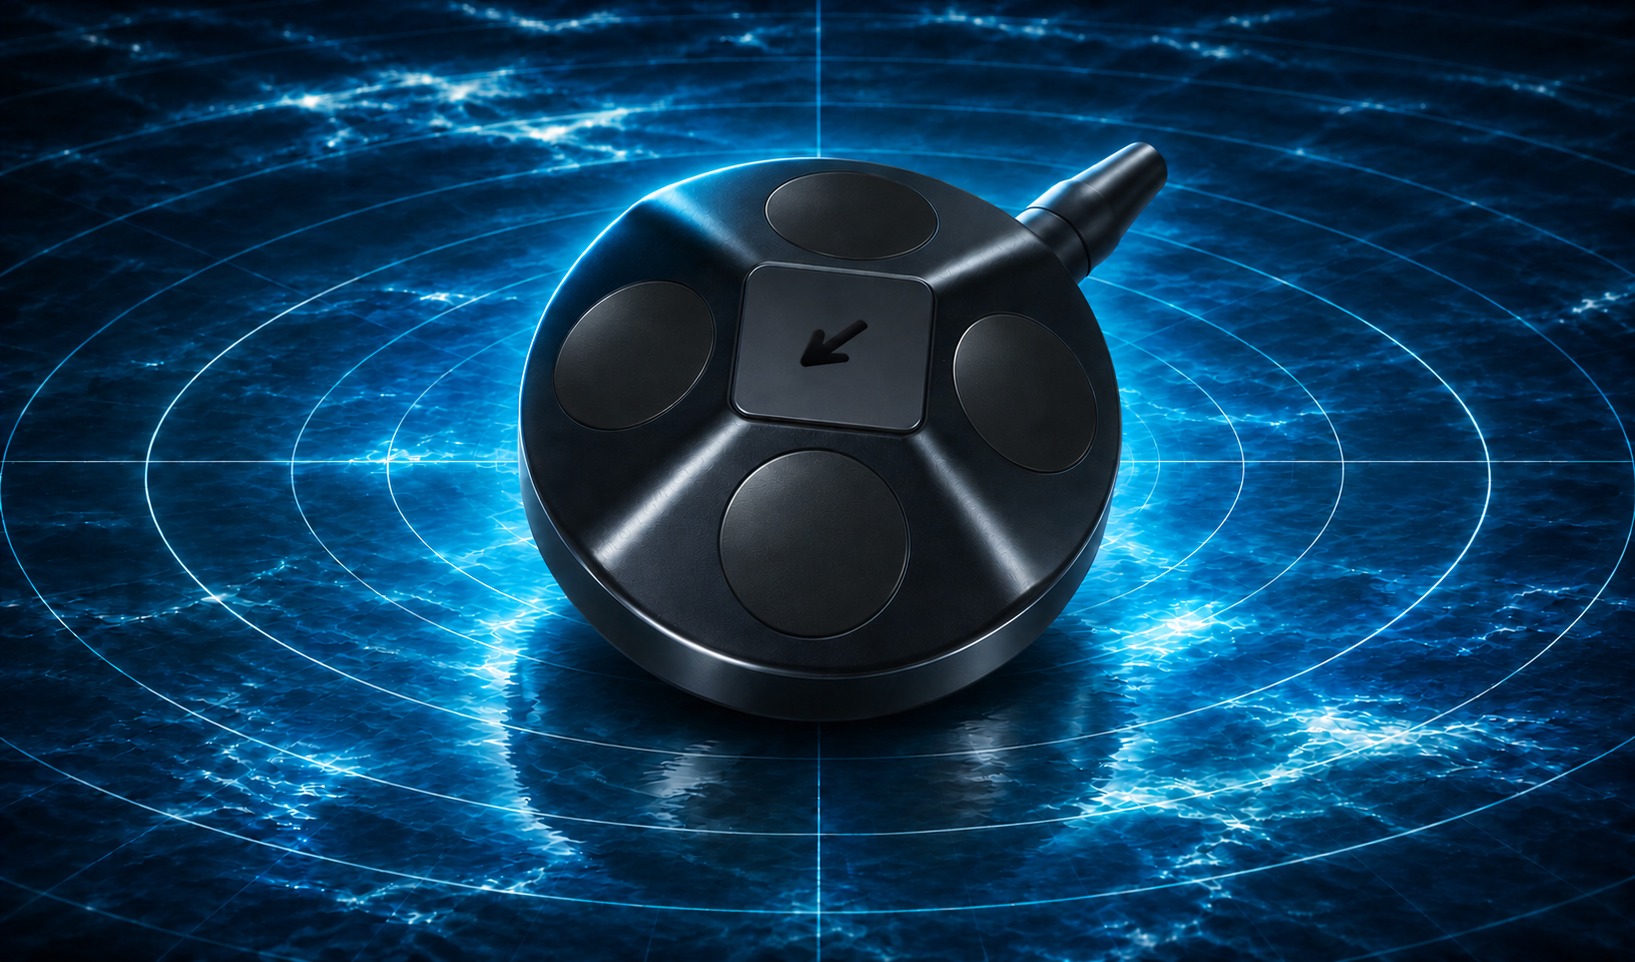
About this product
The H1000 DVL measures an underwater vehicle’s three-dimensional velocity relative to the bottom and provides bottom-clearance information. These data support motion control, navigation, positioning and station keeping. Its compact size is particularly suitable for platforms with limited installation space and for ROVs operating in confined areas.
The sensor combines broadband signal processing with integrated analogue and digital electronics and acoustic transducers. Data are available via UART or Ethernet in PD6 and EPD6 formats. With up to 20 updates per second, the DVL can supply regular measurements to the vehicle controller. The usable bottom-tracking altitude depends on factors including bottom conditions and water salinity.
Applications AUVs, ROVs and crewed submersibles for underwater searches, structural inspection, maintenance and surveillance.
Technical specifications
| Operating frequency | 1,000 kHz |
|---|---|
| Optimal measurement accuracy | ≤ ±0.4% ±5 mm/s |
| Velocity range | ±5 m/s |
| Maximum update rate | 20 Hz |
| Maximum bottom-tracking altitude | Typically 45 m; above 35 m, dependent on bottom conditions and salinity |
| Minimum bottom-tracking altitude | 0.05 m |
| Power supply | 24 VDC nominal; range 18–30 VDC |
| Average power consumption | ≤5 W |
| Interfaces | UART and 100-Mbit/s Ethernet |
| Data formats | PD6 and EPD6 |
| Dimensions Ø × H | 92 × 33.4 mm |
| Weight in air / water | 445/115 g |
| Maximum operating depth | 300 m |